Fleet operations
Bring device health, task state, alerts, and historical activity into a useful operating view.
 SPACETECH7
Robotics and autonomy
We design the control, perception, fleet, and operator layers that help people work safely with intelligent machines.
Discuss this service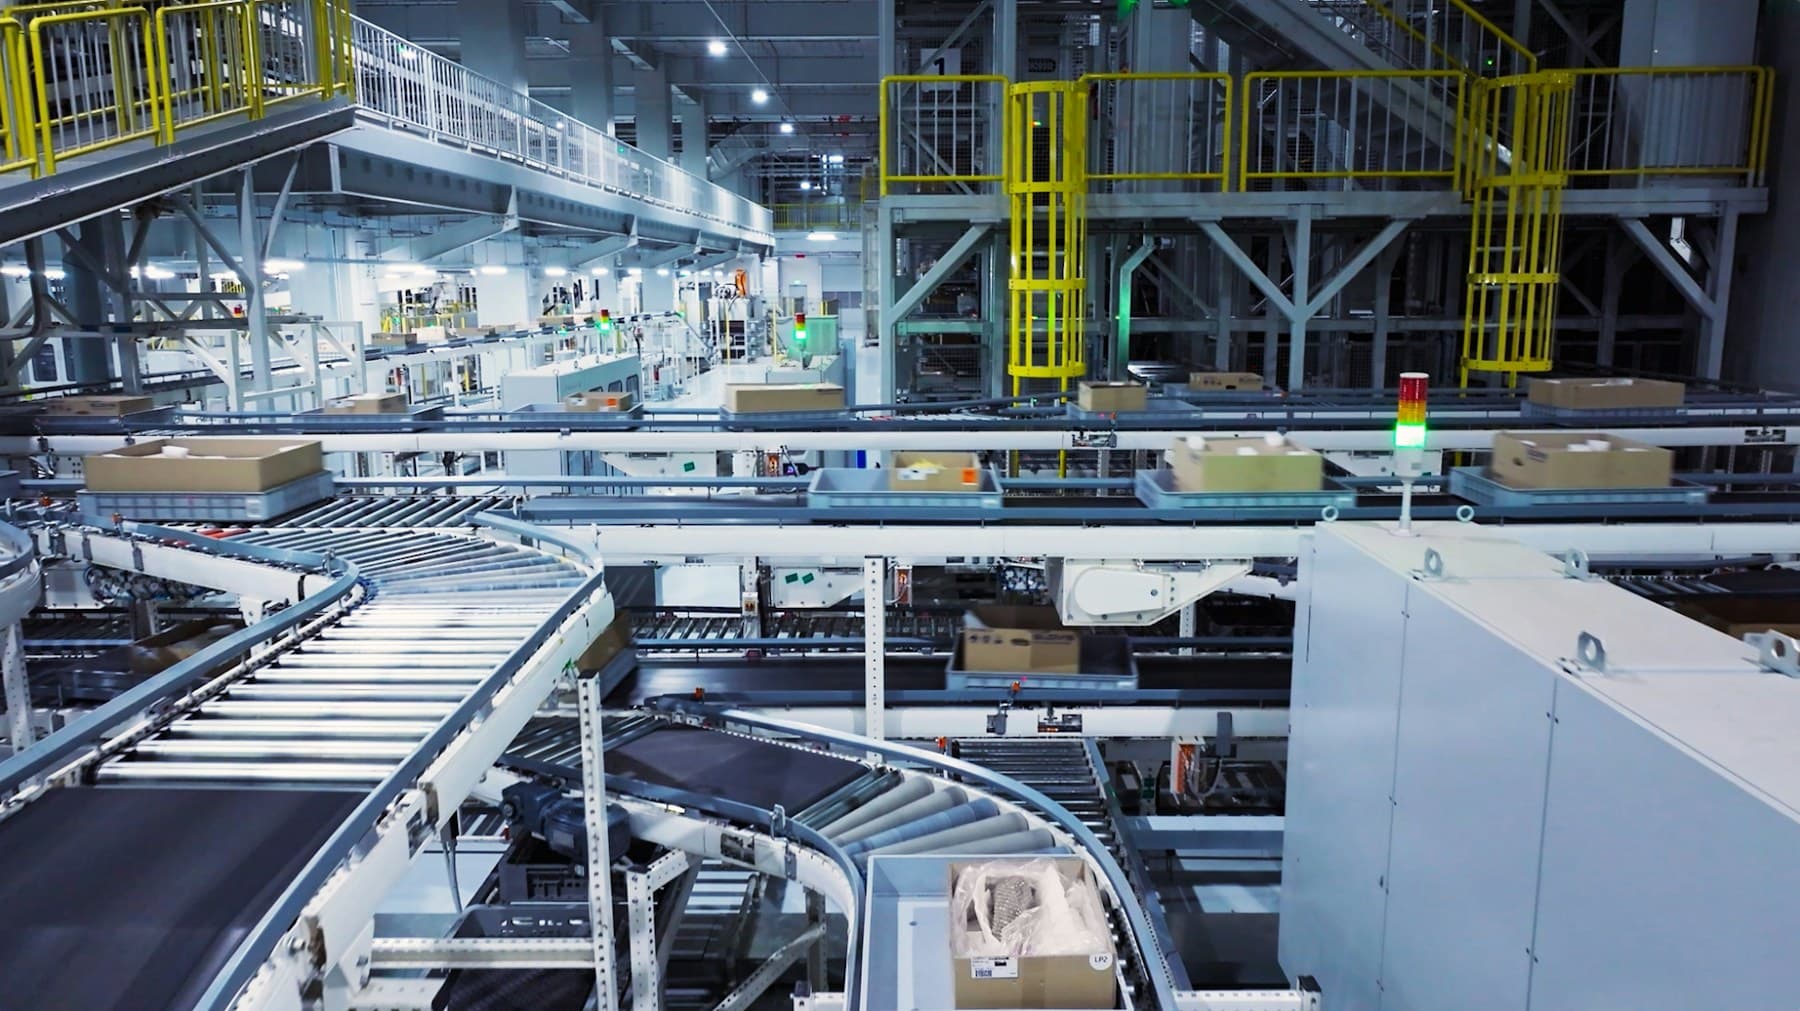
WHAT WE BUILD
We focus on the human and operational layer around autonomy: state, oversight, interventions, evidence, and a clear next action.
Software for the people operating robots, fleets, and connected equipment. We focus on system state, operator control, simulation, and clear intervention workflows.
Bring device health, task state, alerts, and historical activity into a useful operating view.
Show what the machine is doing and give people a defined path to pause, review, or intervene.
Replay events, test interface behavior, and examine unusual operating conditions before a release.
Bring the hardware or simulator interface, sample telemetry, intended operator roles, and boundaries for commands. Domain specialists should define the physical safety requirements.
Our scope is software. We work with a hardware or domain team on the control interface, data contracts, operating model, and integration requirements.
A simulator, recorded telemetry, or a documented device API can support early interface and integration work. Hardware testing is then planned as a separate integration stage.
We define which states allow each action, how confirmation works, what feedback the operator receives, and how the intervention is recorded for later review.